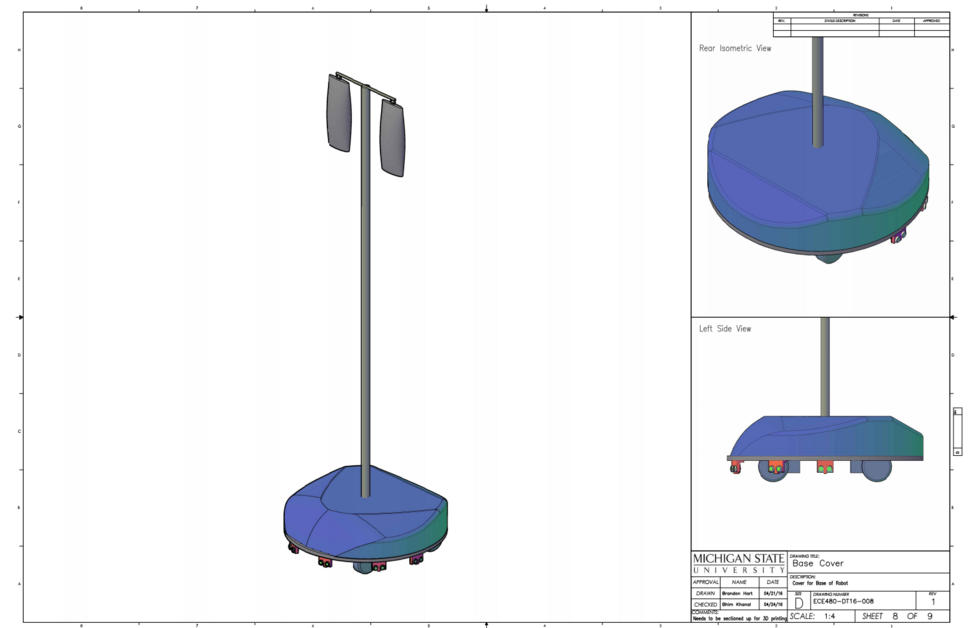
IV Assistant Robot - Summary
In hospitals, a steel pole with four to six caster wheels is used to carry Intravenous (IV) pouch attached to patients when they need any mobility outside of their beds. These IV poles are deceivingly unstable and difficult to move, especially for disabled or otherwise incapacitated patients. This causes an unfavorable situation where patients must either struggle to move while on IV therapy, potentially tripping and falling, or must move with the help of a healthcare professional which is inhibitive to both the patient's independence as well as the health care personnel's time and efforts. In this project, we addressed this issue by replacing the traditional IV pole with an autonomous robot that can carry the IV equipment while following the patient and avoiding collisions. In the process, we have also developed an indoor tracking system capable of tracking and following an object with an accuracy of approximately 10 cm, which can be used in other applications, outside of intravenous therapy or health care entirely. This paper documents the development process and the outcome of the project along with the suggestions for future improvements and alternative applications of the tracking system developed during the project.