Design
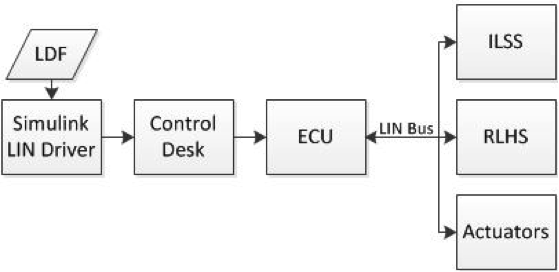
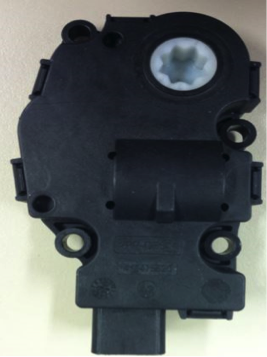
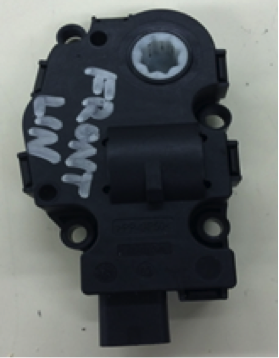
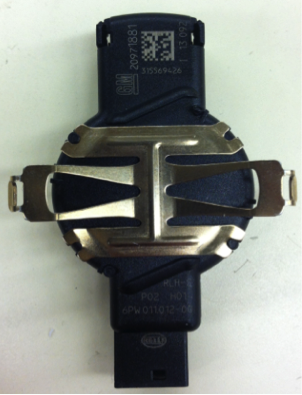
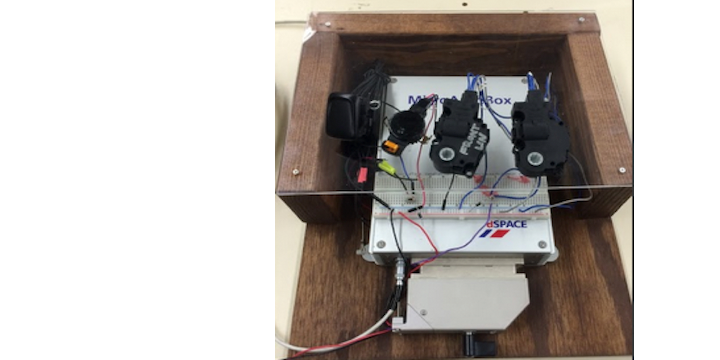
Currently, GM does not have a LIN driver to read the environmental conditions from their sensors. They also do not have a LIN driver to properly send a signal to an actuator and read the speed of the actuator through signal transmission via the LIN bus. Using the LDFs provided by GM, the team is capable of simulating and testing one sensor or up to four actuators at a time. This is due to the LDF having node identifiers, frame, and signal characteristics for only one vehicle component. This design strategy would require the team to design three different Simulink drivers: One for each of the sensors and one for the three actuators provided by GM. These drivers will then be simulated individually in Control Desk to test signal propagation from the LIN master to the single slave. This design establishes the foundation of LIN bus communication but does not utilize the single master multiple slave performance benefit that the LIN protocol was developed for. A flow chart of this design can be seen in the first image.