Our research focuses on reliable video intelligence and multimodal learning, with a particular emphasis on physical intelligence from human-centric videos. We address fundamental challenges in learning physically grounded representations of humans and their interactions with objects and environments, modeling and generating physical interaction dynamics, integrating symbolic knowledge for reliable video understanding and reasoning, and transferring knowledge from human experiences to embodied intelligent systems. Our work spans human motion and human-object interaction modeling, video understanding, generative modeling, and embodied AI.
- (Representation) Human Representation Learning: How can machines learn comprehensive and physically grounded representations of humans and their interactions?
- (Generation) Neuro-symbolic Video Generation: How can machines learn and model physical dynamics by integrating neural generation with symbolic knowledge to produce physically plausible and verifiable videos?
- (Understanding) Reliable Video Understanding: How can machines understand and reason about complex video events while providing verifiable evidence to support their interpretations?
- (Interaction) Human-centric Embodied AI: How can intelligent agents leverage knowledge learned from human experiences to adapt and interact with the physical world intelligently and reliably?
-
Human Representation Learning
Structured Representation. How can machines learn comprehensive and physically grounded representations of humans and their interactions?
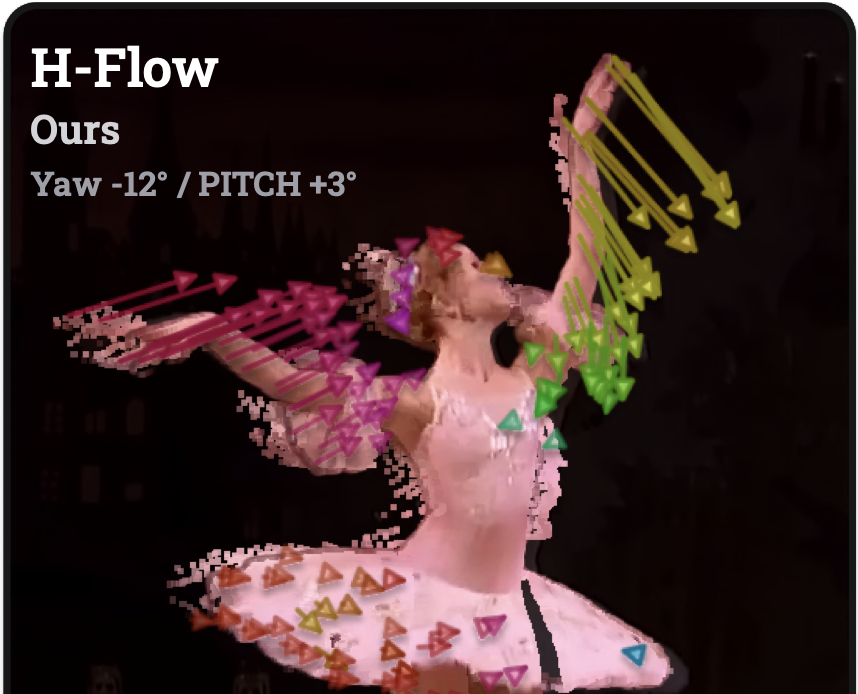
-
Neuro-Symbolic Video Generation
Dynamics Modeling. How can machines learn and model physical dynamics by integrating neural generation with symbolic knowledge to produce physically plausible and verifiable videos?
-
Reliable Video Understanding
Semantics Understanding and Reasoning. How can machines understand and reason about complex video events while providing verifiable evidence to support their interpretations?
-
Human-centric Embodied Intelligence
Action and Adaptation. How can intelligent agents leverage knowledge learned from human experiences to adapt and interact with the physical world intelligently and reliably?

