With the widening availability of RGB-Depth
cameras to industry and to consumers, new
applications for these sensors are in high
demand. World modeling is one such application and, while
done before in various research projects, the process of using
RGB-Depth cameras to model a space has yet to become an
automated process. Automating this process would allow for
numerous practical applications ranging from military use to
helping those with physical disabilities.
The goal of this project is to combine a robotic moving
platform and a commercially available RGB-Depth camera
to autonomously build a 3D model of a room. The combined
device will require additional structural supports and power.
A successful device will be able to localize its position when
capturing images and integrate images together to build a 3D
model. The robot should be able to completely map a room
without getting stuck or running out of power and should do
so in a timely manner.
Several challenges had to be addressed while working
on this project including integrating the various pieces of
hardware together, solving the mapping and localization
problem, and combining the data from the RGB-Depth
sensor into a cohesive and complete 3D model in real-time.
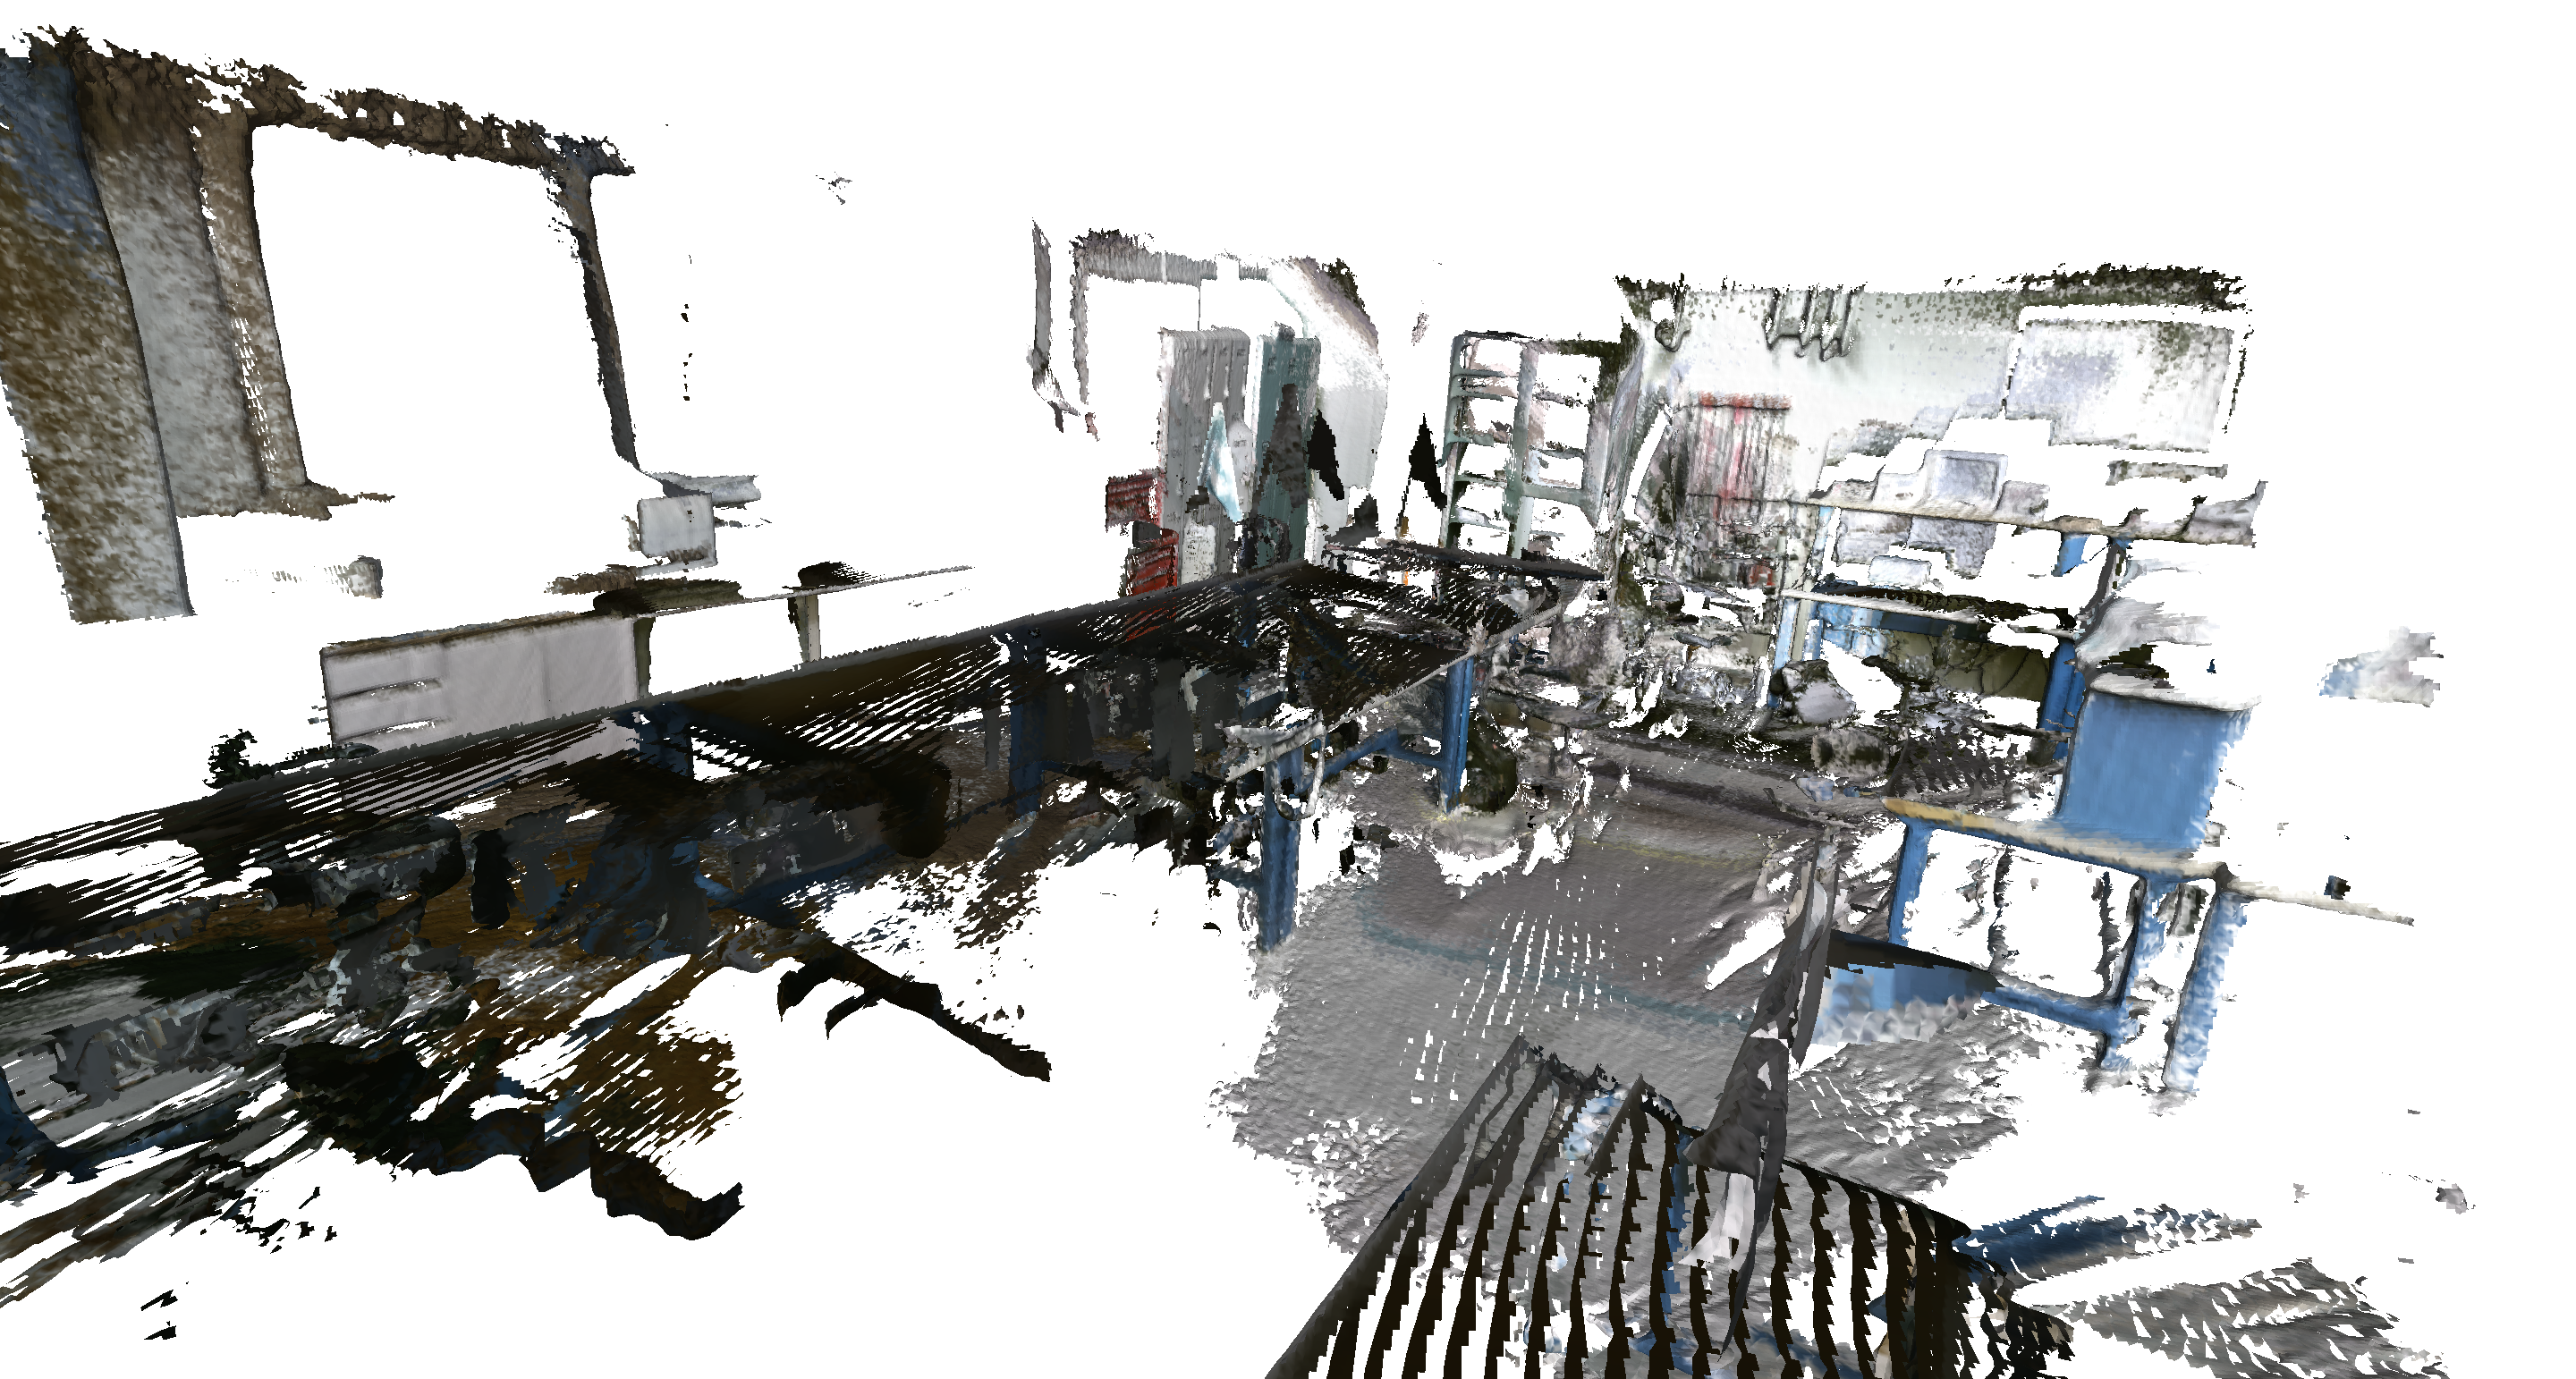
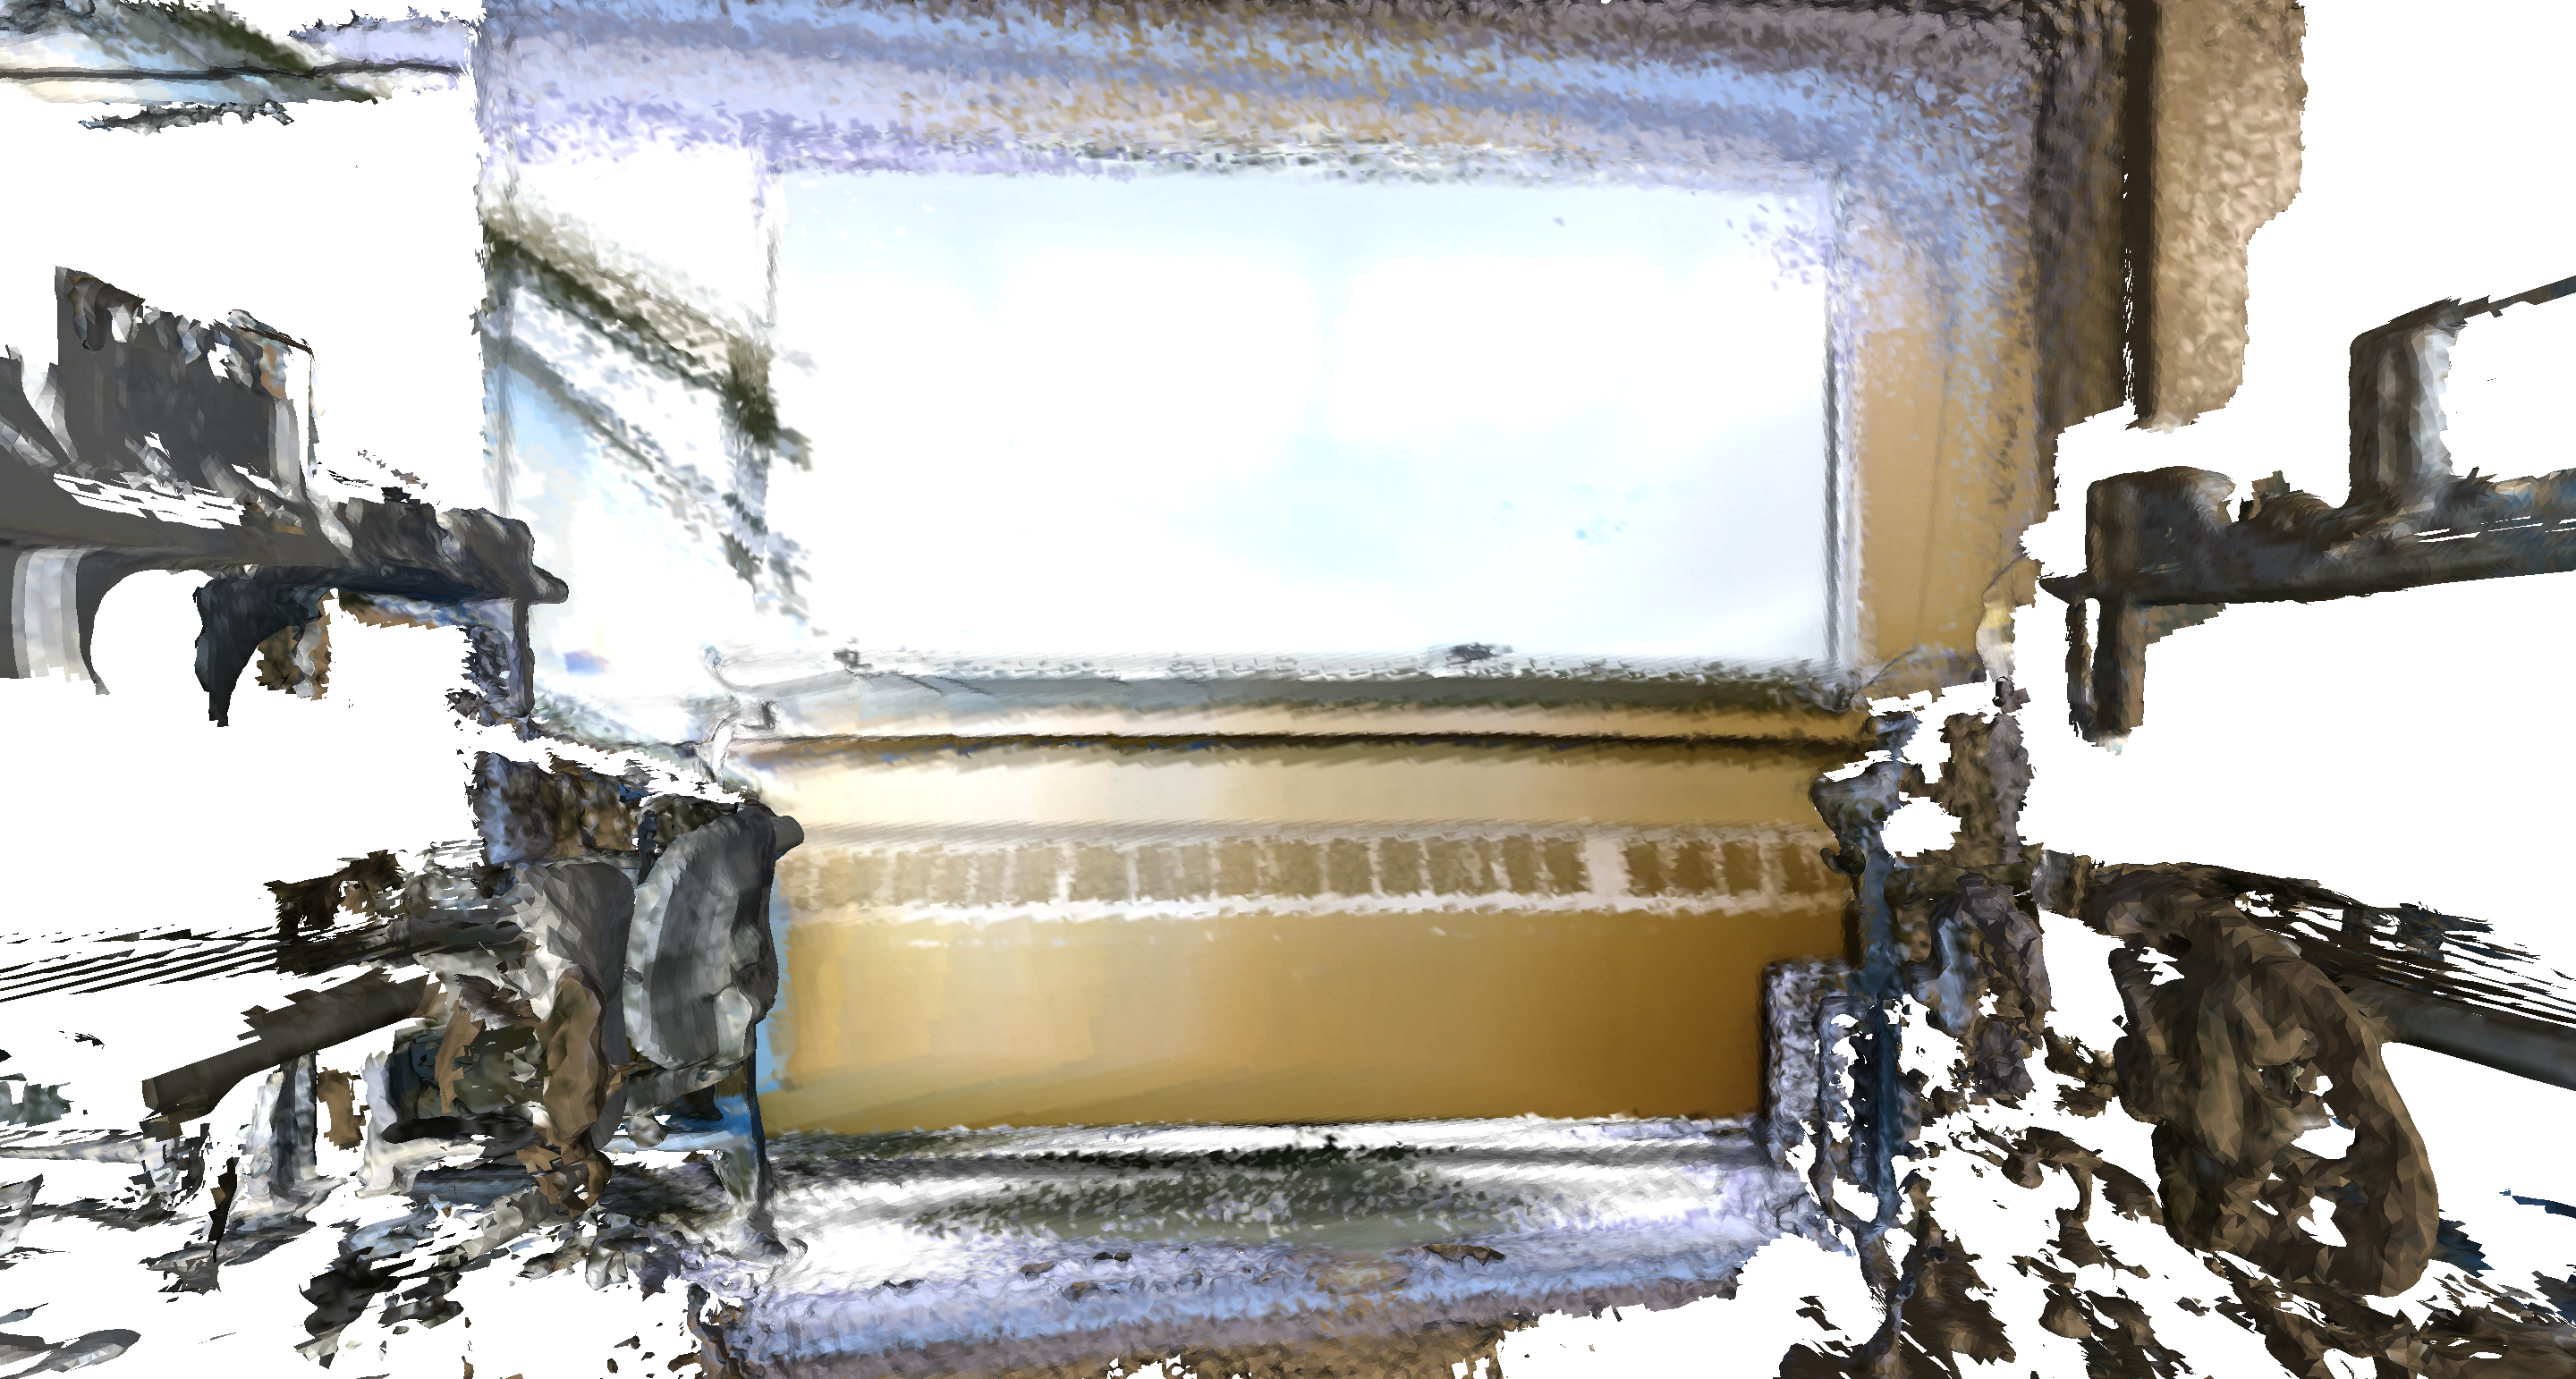
Pictured on right: an example of a 3D model of a room along
with both the RGB-Depth sensor (Microsoft Kinect V2) and
robotic platform (iRobot Create 2) used in the project.
Click this link to view a video of the robot in action.