Overview
Agricultural robotics is an aspect of farming and agriculture that is growing rapidly as technology gets more in depth. The idea of an agBOT (Agricultural Robot) is simply to take over the “mindless” work of planting seed over great distances; a job that farmers face day in and day out.
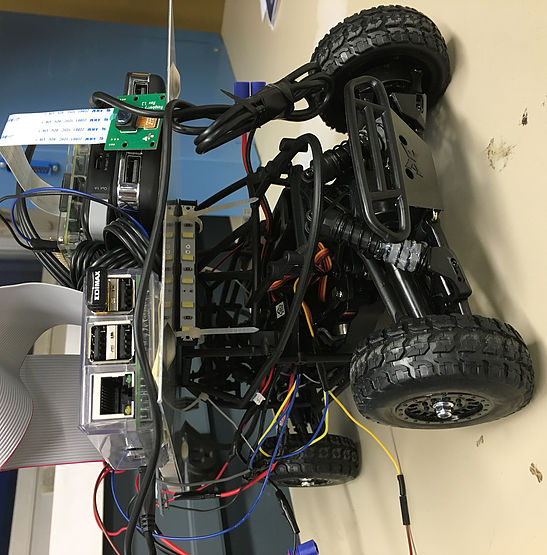
As part of Design Group 10, our goal is to manufacture, from the ground up, a scalable prototype of an agBOT. This scalable finished product will be size of an RC car, and the technologies we incorporate will be easily transitioned to a full size agBOT. (A truck, bobcat, etc.). When done with our prototype, a future team will be able to clearly see our design of the agBOT, a detailed layout and schematic of its subsystems, and our overall intent for the future of how the agBOT should function.
In the end, we plan to improve observation, intervention, and analytic data storage within agricultural work methods. This robot should be able to provide real time video feed while it works, and be able to drive itself to user-inputted GPS coordinates.
>
Sponsor
Michigan State University
Electrical and Computer
Engineering Department
Facilitator
Dr. Nelson Sepulveda