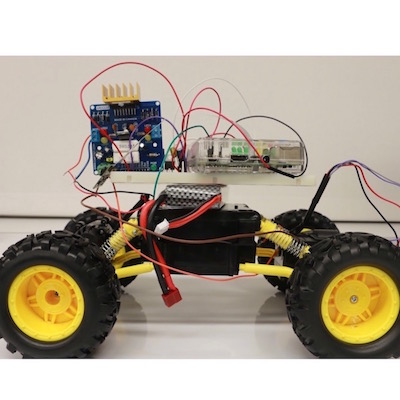
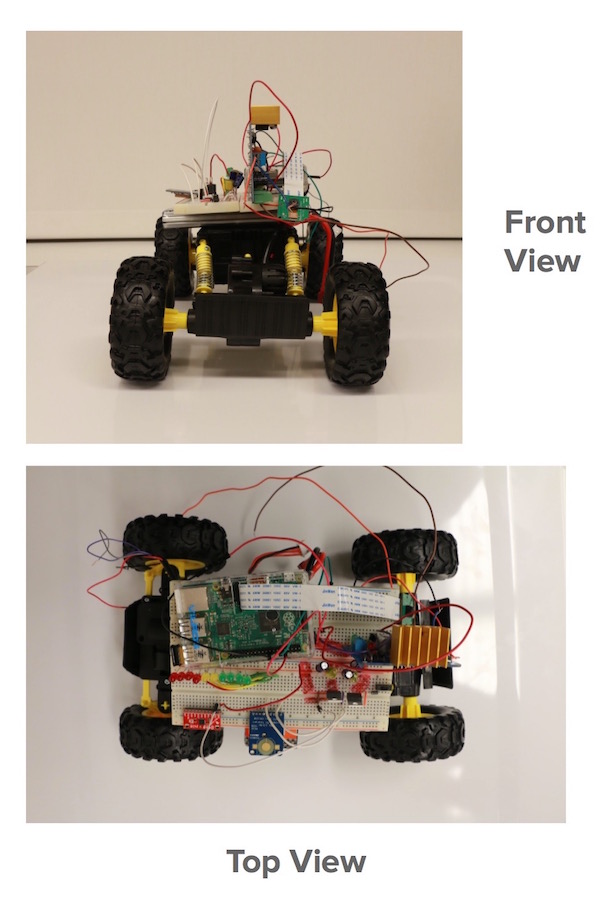
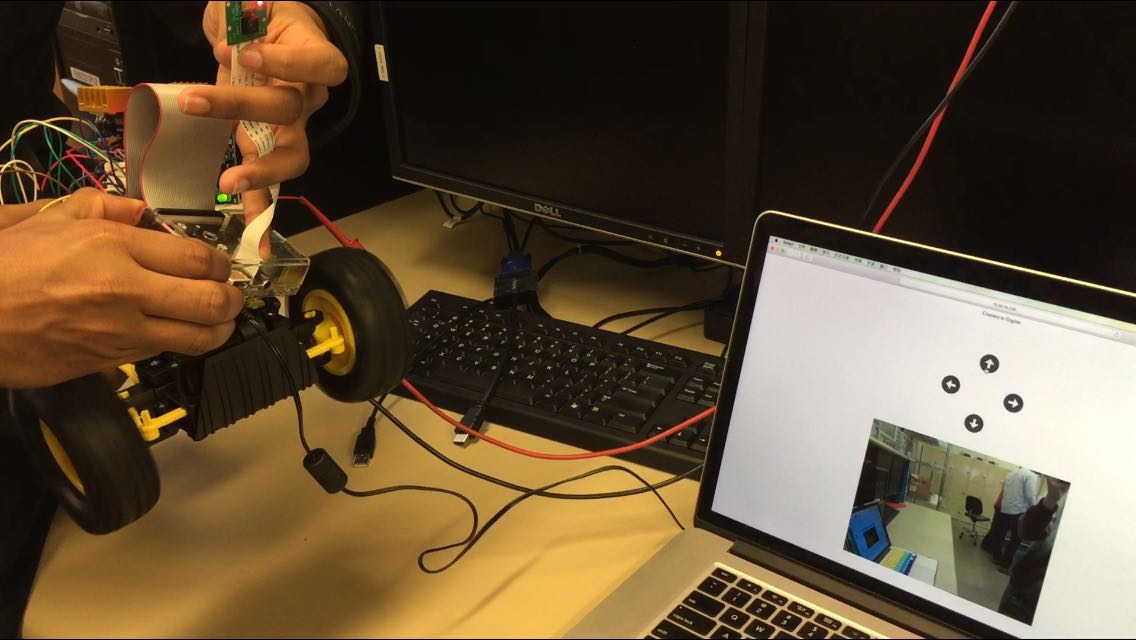
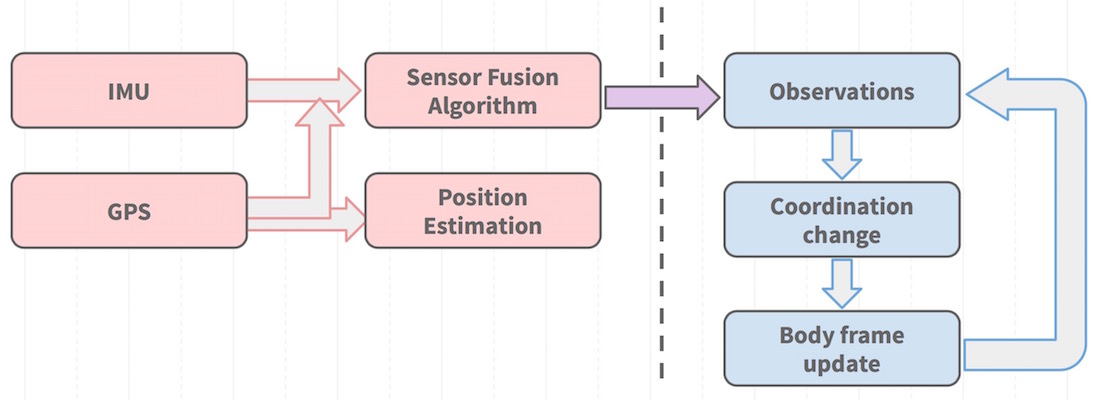
Design Team 8 is going to design a scaled version of an unmanned agriculture robot which can plant seeds by itself in the farm and perform various other unmanned functions on the field. The AgBOT also needs to send back data from the field, such as seed rate fertilizer rate etc, back to the farmer. In order to achieve the goal of creating an unmanned seeding device, GPS navigation and remote control functions have to be set up on the robot. A base station will be created to receive the live video and data from the robot. The user should also be able to monitor and control the robot at the base.
We love engineering